
Table of Contents
Designing mobile equipment involves a lot of factors to consider. Equipment such as automated guided vehicles and autonomous mobile robots needs to move smoothly within a workspace, which often means its size and structure are tightly constrained. Under these design constraints, where to place each required component and how to connect them becomes a critical factor that shapes the equipment’s entire structure.
Logistics equipment in particular has to repeatedly transport loads of varying weights. When the internal components take up more volume and the equipment’s overall weight increases, it becomes harder to reduce height and width, and response times when starting, stopping, or changing direction can slow down as well. Since this can affect the equipment’s mobility and operating efficiency, keeping the drive unit as compact as possible is an important consideration in automation equipment design.
In line with this trend, more design teams are now looking at the drive unit as a single module rather than a combination of individual parts. Integrating core drive components such as the motor and reducer makes it possible to use the equipment’s internal space more efficiently and configure the drive unit more flexibly to match the equipment’s structure and operating conditions.
In this article, we’ll look at why logistics equipment needs a robot drive module and the requirements the field actually demands, then walk through the advantages the BCSA actuator can offer for equipment design.
Why Does Logistics Equipment Need Modularization?
A robot drive module brings together all the drive components needed to create equipment’s movement into a single unit. Unlike an approach where individual parts are selected and assembled separately, a robot drive module allows core drive components such as the motor and reducer to be reviewed together as an integrated whole. This reduces the burden of checking installation space and connection structures for each part separately and makes it possible to adjust the drive unit configuration more efficiently to fit the equipment’s structure.
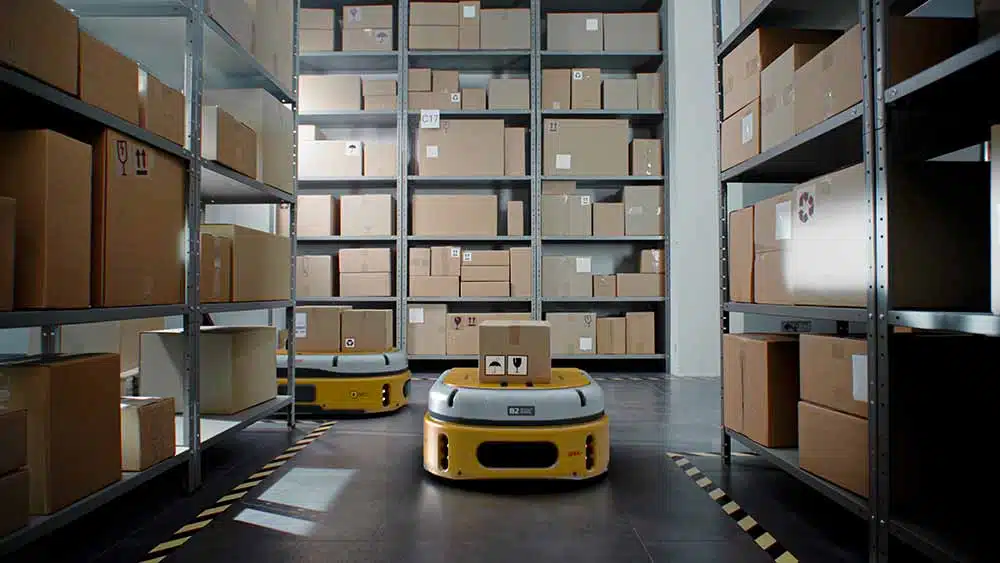
The reason this modular approach is being considered for logistics equipment comes down to how tight the internal space is. Automated equipment such as automated guided vehicles and autonomous mobile robots needs to fit not just the wheel drive unit for movement, but also a battery, control unit, sensors, and more. Since all of these components have to be arranged within a limited space, the proportion of that space taken up by the drive unit has a direct effect on the equipment’s overall design.

The wheel drive unit positioned at the bottom of the equipment is a particularly space-constrained area. If the wheel drive unit gets larger, it becomes harder to lower the equipment’s height, and the layout of internal parts and connection structures may need to be adjusted as well. If this makes the structure around the wheels more complex, it can also affect interference with external structures. Ultimately, how the drive unit is configured can influence the equipment’s size and height, its internal design, and even its driving stability.
This is where a robot drive module plays an important role in increasing design freedom. It makes efficient use of the space at the bottom of the equipment, simplifies the structure around the drive unit, and allows the drive unit configuration to be adjusted flexibly for different equipment models. As equipment is increasingly required to have a smaller, more efficient structure, the need to design the drive unit as a robot drive module will only continue to grow.
The Key Requirements of a Robot Drive Module That Increase Design Freedom
A robot drive module applied to logistics equipment needs to deliver the required torque reliably, even in environments where load conditions keep changing. Logistics machinery can experience momentary stress on the drive unit when it starts or stops while carrying a load, changes direction in a narrow space, or passes through a sloped section or a stretch of flooring with different conditions. Since load concentrating on a specific part can affect drive stability, the drive unit’s internal structure needs to be able to distribute repeated loads evenly.

How the drive unit handles repeated operation matters too. Inside a logistics center, equipment moves and stops many times over the course of a day, repeating the same motion for long stretches of time. If the drive unit’s output torque isn’t consistent throughout this process, driving quality can suffer or operating efficiency can be affected. This is especially important in environments where multiple units of equipment run at the same time, where reducing performance variation between drive units and maintaining consistent motion quality becomes essential.
Logistics equipment is also often developed in several specifications depending on load capacity or intended use. Even the same mobile platform, for example, can require different drive performance depending on the weight of the items it carries or any additional functions it needs to support. Configuring the drive unit as a robot drive module makes it possible to respond to these changes by selecting or adjusting a robot drive module that fits the requirements, rather than redesigning the entire drive unit every time the equipment specification changes. This helps reduce the burden of design changes when expanding a product lineup.
In short, a robot drive module used in logistics equipment needs to account for both space efficiency and drive performance at the same time. It needs to deliver the required torque reliably within a limited equipment size, maintain consistent performance under repeated operation, and adjust its configuration to match changes in equipment specifications. When these conditions are met, a robot drive module can serve as a factor that increases the design freedom of automation equipment.


Why the BCSA Series Is a Good Fit for Automation Equipment Design
The key component within a robot drive module is the actuator. The actuator is responsible for generating the force the equipment needs, and it has a direct effect on the module’s output performance and range of application. That means achieving a compact robot drive module requires an actuator that can deliver sufficient torque output even within a limited space.
Bonsystems developed the BCSA actuator series to meet exactly this kind of design requirement. The BCSA V4 is an actuator built on our proprietary cycloidal reduction technology. Because it delivers high torque output even in a slim structure, it can be considered a suitable drive solution for logistics equipment that needs to configure its drive unit within limited space.
When a slim actuator reduces the space the drive unit takes up, that freed-up space can be used for additional components or an extra battery. This helps extend the equipment’s operating time and reduces the downtime burden caused by charging or battery replacement. In turn, it also has a positive effect on equipment productivity and the operating efficiency of an automated system.

The BCSA is also built with a structure designed for stable torque transmission. Logistics equipment needs to account for both changes in load weight and repeated driving conditions. The V4 incorporates a cycloidal reduction structure into its design for exactly this reason. Its power transmission method, in which a cycloidal-curve gear rotates in a rolling motion, spreads the load broadly and reduces the concentration of stress on any one part even during repetitive operation. This structure helps secure the drive unit’s durability and maintain more consistent performance over time.
The BCSA’s pinless structure can also be an important advantage for logistics equipment. Pinless cycloidal technology refers to a design that removes the pin components to reduce the part count and simplify the structure. Fewer parts and assembly elements mean fewer variables to manage during manufacturing, which also helps improve consistency in quality across units.
With its slim structure, stable torque transmission, and pinless-based structural simplification, the BCSA is a solution worth considering for the drive unit design of a wide range of robots and automation equipment, including automated guided vehicles and autonomous mobile robots.
Bonsystems continues to develop actuators and robot drive modules based on cycloidal reduction technology for use in robots and logistics machinery. If you share the installation space, required torque, and operating conditions for the equipment you’re developing, we can propose a drive solution tailored to your equipment’s structure. If you’re weighing actuator options while designing logistics equipment, or if you’d like additional materials on the BCSA V4, please reach out to us through our website.

FAQ
Q. Why is drive unit modularization being considered for logistics equipment?
Logistics transport equipment has to handle movement, loading, and transfer functions all within a fixed space. If the drive unit is built from individual parts, installation space, wiring, and mounting structures each need to be reviewed separately, which can make the design more complex. A robot drive module allows these components to be reviewed as a more integrated unit, making it possible to arrange the drive unit flexibly to fit the equipment’s structure and helping increase design freedom.
Q. What advantages does applying a robot drive module offer in automation equipment design?
Applying a robot drive module makes it possible to configure core drive components, such as the motor and reducer, as an integrated structure. This simplifies the internal layout of the equipment and allows the drive unit configuration to be adjusted more efficiently when a model’s specifications need to change. This can be especially helpful in reducing the burden of design changes when developing multiple types of equipment.
Q. What factors should you look at when choosing an actuator?
When selecting an actuator for a piece of equipment, you need to look at torque output as well as whether it has a slim enough structure to fit within the equipment’s limited space. If an actuator is too thick, it reduces the internal space available, complicates component layout, and can limit how much the equipment’s height or width can be reduced. That’s why it’s important to consider whether the actuator can deliver the required torque reliably while also having a structure that eases the burden on equipment size and internal layout.
Q. In what kind of equipment environment can the BCSA V4 be considered for use?
The BCSA series is an actuator designed to deliver high torque output even in a slim structure. It can be considered for configuring the drive unit in space-constrained locations such as the bottom of the equipment or around the wheels, and by reducing the proportion of space the drive unit takes up, it frees up room for other components like a battery or control unit. It’s also built on a cycloidal reduction structure that accounts for stable torque transmission and load distribution at the same time, making it a suitable option for the drive unit of logistics equipment that has to handle heavy, repetitive workloads.
Q. What information should you prepare when inquiring about a BCSA actuator?
When inquiring about an actuator product, it helps to first summarize the environment your equipment operates in and the specific motion it needs to perform. The torque or speed your equipment requires can vary, for example, depending on the installation space available and the load capacity it needs to carry. Providing this information up front lets us review actuator specifications and drive unit configurations tailored to your equipment’s structure more quickly.
