
Table of Contents
Ever since the word “robot” first appeared, robots have been imagined as machines that take over human labor and make life easier. Carrying out repetitive, physically demanding work and easing the burden on people remains one of the most important roles robots play today.
Early robotic automation developed mainly around tasks performed at a fixed position, repeating the same motion again and again, such as assembly or welding. As production scale grew and processes became more specialized, the amount of transport work involved in moving materials and products to the next stage began to increase as well. Fixed industrial robots, however, can only operate within a limited working radius, so the task of connecting separate processes still had to be handled by people.
Mobile robots developed to make up for this limitation. Unlike the earlier approach, where a person had to bring items to the robot, an autonomous mobile robot can travel directly to wherever the work is needed. Because of this, the range robots operate in has gradually expanded from fixed workstations to real-world spaces such as buildings and cities.
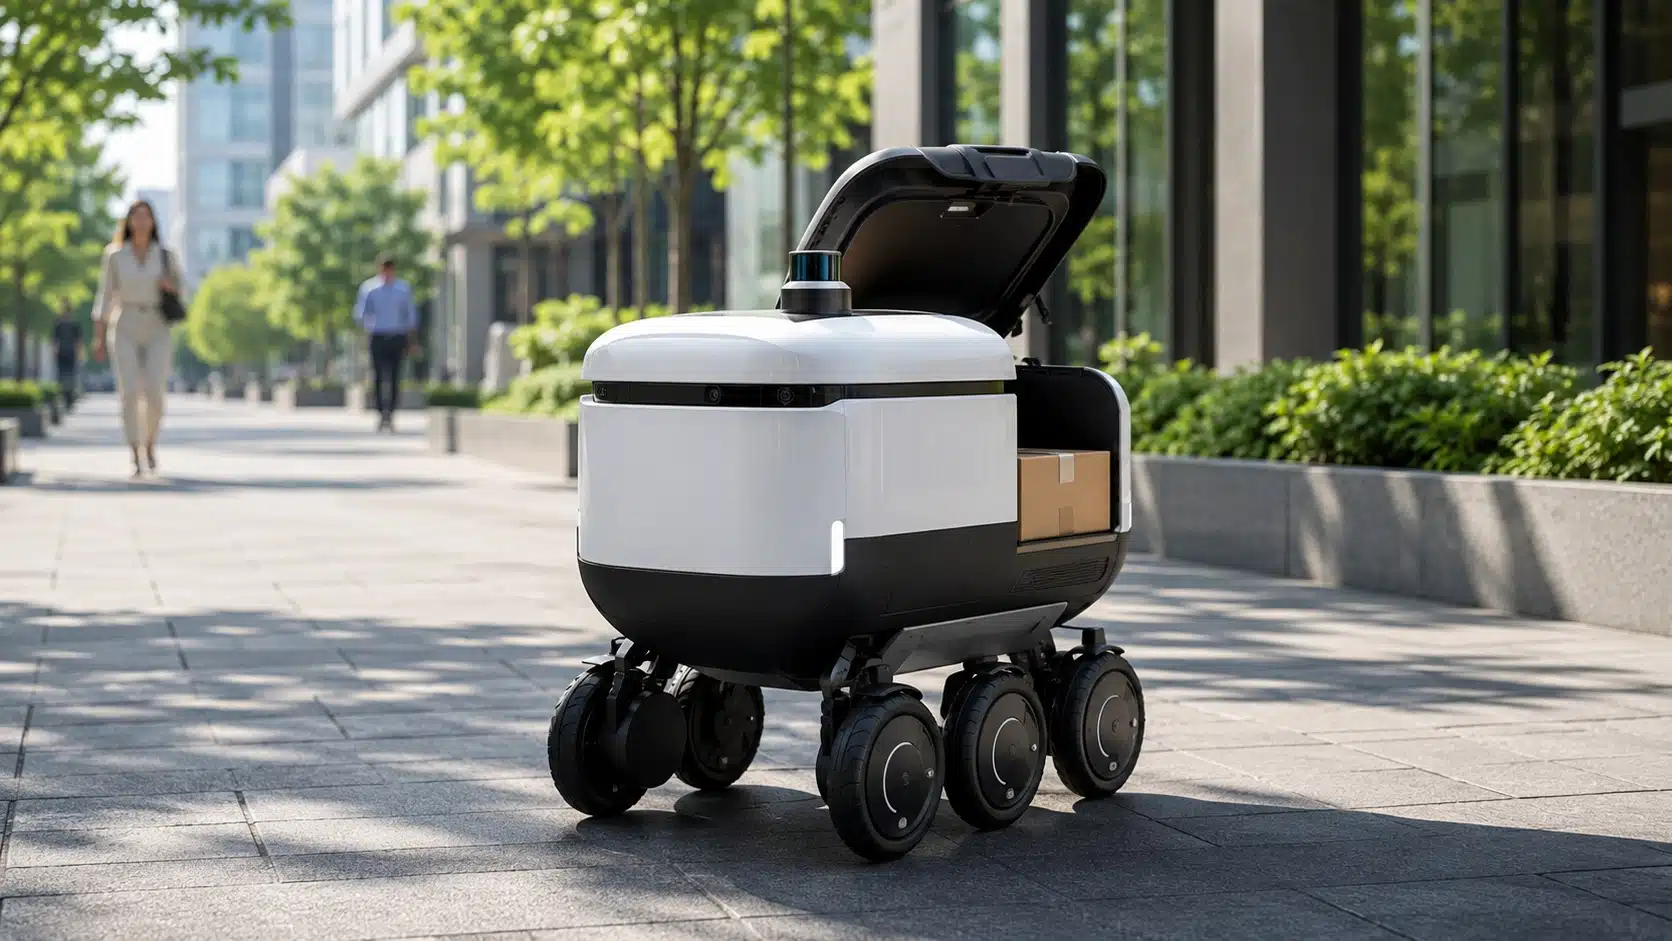
Core Elements That Drive Autonomous Mobile Robots
A mobile robot is a robot that uses autonomous driving capabilities to interact with its surroundings and carry out the tasks it’s assigned. Because it can set and adjust its own travel path, it’s now used in a wide range of settings, from transport work in logistics centers to delivery, guidance, and patrol.
An autonomous mobile robot uses sensors and AI technology to read its surroundings, plan a travel route, and then move according to its purpose. This process brings together several elements in a coordinated system, from the sensors that gather information about the surroundings, to the system that calculates the travel route, to the technology that governs movement and ultimately drives the robot.
Sensors collect the information a robot needs to understand its surroundings. LiDAR, ultrasonic sensors, and cameras are used to detect the surrounding space and obstacles, and a mobile robot combines this sensor data to tell the difference between space it can move through and obstacles it needs to avoid.
Once its current location and destination are confirmed, the robot calculates a route to the destination based on information about its surroundings. This calculation takes into account not only available paths and the location of obstacles, but also the robot’s size and turning radius. If a person or object appears and the existing route becomes unusable, the robot can recalculate its path and respond flexibly.

The robot’s control system adjusts its speed and direction according to the calculated route. These control commands are then carried out by the drive unit, where the actuator, the drive unit’s core component, converts the control signal into the torque the robot needs to actually turn its wheels.
Through this combination of technologies, autonomous mobile robots can be put to good use in spaces where conditions change frequently and outcomes are hard to predict. As the underlying technology continues to advance, the range of spaces and tasks these robots can take on is expected to expand even further.
The Challenge for Mobile Robots: Operating Time
Autonomous mobile robots already bring a range of conveniences to everyday life and industrial settings. But there are still challenges to solve before they can be used reliably in the real world.
Because mobile robots are, by nature, difficult to keep connected to a power cable, most of them run on batteries. A battery has to supply power not just to the drive unit, but also to the sensors, controller, communication devices, and other components inside the robot. As travel distance or load capacity increases, the power required can increase along with it.

The most direct way to extend operating time is to use a larger battery. But a bigger battery compartment leaves less room for other components, such as sensors, the controller, and the drive unit. A larger battery also adds to the robot’s overall weight, which in turn requires more energy to move.
A smaller battery, on the other hand, allows for a lighter, more compact robot design, but it shortens operating time and forces the robot to stop work more often to recharge. In logistics and delivery work, these interruptions can lead to delays and lower operating efficiency. This becomes even more critical as mobile robots take on tasks tied directly to human safety, such as search and rescue, disaster response, and security patrol, making sufficient operating time increasingly important.
For this reason, an autonomous mobile robot has to secure both enough operating time and the drive performance it needs, all within a limited size. That’s why the size and placement of internal components, the robot’s overall weight, and the drive unit’s output all need to be considered together.
The Answer to Mobile Robot Design: The BCSA Actuator
Bonsystems recognized this need and developed the BCSA V4, a slim actuator built to fit into tightly constrained internal spaces. The BCSA delivers high torque even within a thin structure, increasing how efficiently a robot’s internal space can be used and making it easier to arrange other components, such as the battery and sensors, more effectively. When the drive unit takes up less space, an additional battery can be installed instead, which can help extend a mobile robot’s operating time and improve operational stability.

Alongside reducing the actuator’s size, wiring is another factor that needs attention during the design process. Since the motor, sensors, and controller inside a robot all need to exchange signals with one another, how the connecting cables are routed also affects the overall design. To address this, the V4 uses a hollow-shaft design that allows communication cables and other wiring to pass through the actuator itself. This reduces the amount of wiring exposed on the outside, keeps the structure around the drive unit simpler, and lowers the risk of cable interference during movement.
An actuator for a mobile robot also needs enough durability to withstand repeated operation and load, on top of a structure that makes efficient use of internal space. The BCSA V4 uses a cycloidal reduction structure that spreads load across multiple contact points, helping it deliver stable torque transmission and durability even in demanding, high-load, repetitive environments.

It also applies a pinless structure that simplifies the internal configuration while preserving the load-distribution and durability benefits of the cycloidal gear. With fewer parts, the assembly process becomes simpler, and there’s less room for part-to-part variation during assembly, which helps maintain consistent quality across repeated production runs. This structure also helps ease the manufacturing burden and improve productivity.
Taken together, these features make the BCSA a slim actuator solution that delivers high torque and design flexibility even within a limited installation space, addressing both a mobile robot’s need for efficient internal space use and sufficient operating time.
Autonomous mobile robots will continue to take on more diverse spaces and environments, spreading further into everyday life and across industries. As that happens, drive technology capable of delivering stable movement in any environment will only become more important.
Bonsystems’s BCSA is a slim, high-torque actuator built to meet exactly that need, offering a solution well suited to a wide range of next-generation robot development. If you’re looking for a slim actuator for a mobile robot, or if you’d like more detailed information on the BCSA, please reach out to us through our website.

FAQ
Q. Why does internal space utilization matter so much for autonomous mobile robots?
A range of components, including the battery, sensors, controller, communication devices, and drive unit, all have to be arranged together inside the robot. When one component takes up a large share of that limited space, it leaves less freedom to place the others. The drive unit in particular tends to account for a large portion of a robot’s internal footprint, so it needs a compact structure that keeps its output performance intact while reducing its size.
Q. What needs to be considered to secure enough operating time for an autonomous mobile robot?
A mobile robot runs on the energy its battery supplies, and power consumption can vary depending on several operating conditions, including the robot’s overall weight, load capacity, and travel distance. When designing a mobile robot, it’s important to look beyond battery capacity alone and also consider the drive unit’s size and weight, along with how internal components are arranged.
Q. What matters most when choosing an actuator for an autonomous mobile robot?
An actuator used in a mobile robot needs to reliably deliver the torque required for movement, even within a limited installation space. In environments with frequent movement and long operating hours, durability that can withstand sustained load is just as important. It’s also worth reviewing whether the actuator’s size and thickness suit the robot’s overall internal structure, since this affects the design freedom available inside the robot.
Q. What advantage does a pinless structure offer in actuator design?
Pinless cycloidal technology simplifies the internal configuration by removing the pin components used in a conventional cycloidal reduction structure. Fewer parts make it possible to organize the production process more efficiently. It also reduces the assembly variation that can occur during manufacturing, which helps maintain consistent quality across mass production.
Q. What benefits can the BCSA offer to mobile robots?
The BCSA is an actuator designed to deliver high torque even with a thin structure. Because this slim design reduces the space the drive unit takes up, it leaves more room to add other components inside the robot. That extra space can be used to fit an additional battery or optimize the layout of internal components, ultimately helping secure both the robot’s operating time and its design flexibility.
References
1. What Are Mobile Robots and How Do They Work? (Novus Hi-Tech)
2. “Military Drones Now Dominate the Battlefield, but Battery Life Is the Bottleneck to Growth” (ZDNET Korea, 2026)
