
Table of Contents
Recently, the landscape of manufacturing plants and logistics warehouses has been changing rapidly. As collaborative robots such as AGVs and AMRs become core equipment driving automation, they are taking over tasks once performed manually, such as transporting, moving, and stacking goods. As the range of applications for automated robots continues to expand, the role of robot reducer companies that supply reducers, one of the key components of the drive system, is becoming increasingly important.
Mobile robots help improve work efficiency in manufacturing and logistics sites by transporting loads ranging from tens of kilograms to several tons. During operation, robots repeatedly accelerate, decelerate, stop, and start, and the load placed on the drive unit varies depending on the weight of the cargo, floor conditions, and travel distance. This means the wheel drive units and joints of a robot need a reducer that can reliably deliver sufficient torque while withstanding repeated loads.
As a result, robot reducer companies continue to develop high-torque, high-durability reducers tailored to the operating conditions of collaborative robots and supply them across a wide range of industrial fields. So in a market for automated robots that is set to expand even faster going forward, what type of reducer would be the most suitable choice? To answer that, it helps to first look at the key requirements for robot reducers.
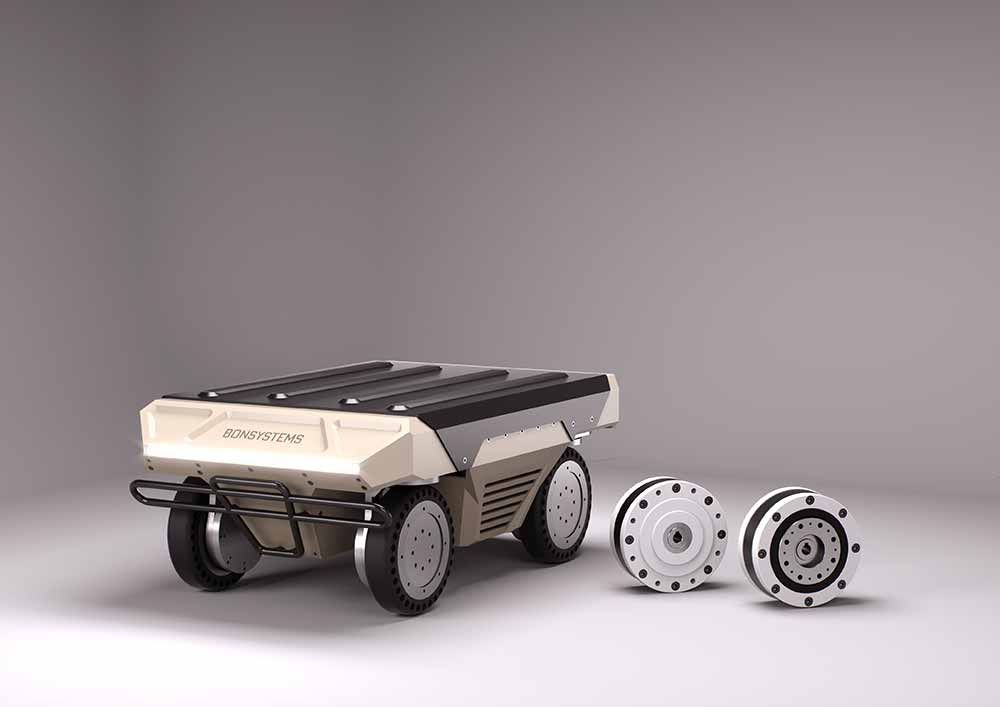
Requirements for Reducers in Collaborative Robots
Because logistics robots must repeatedly carry heavy loads, their drive units require a basic level of durability that can withstand continuous heavy loads. At the same time, the reducer must support the load transmitted to the drive unit while delivering sufficient torque, maintaining stable driving performance across a range of load conditions.
Repeat accuracy is another critical performance factor. Mobile robots operate in environments where acceleration, deceleration, stopping, and starting occur frequently. If positional errors accumulate during this process, driving quality and productivity can decline, so the drive system needs to consistently deliver accurate position and speed even through repeated movements.

Recently, achieving both compact size and high torque at the same time has emerged as an important challenge. As more mobile collaborative robots operate in the same spaces as people, compact designs that reduce installation space while improving mobility and space efficiency have become increasingly important. In environments where robots move through narrow aisles or share pathways with workers, the size and weight of the drive unit have a direct impact on how usable the robot is.
However, satisfying all of these requirements at once is not easy. Generally, achieving high torque and durability tends to increase the size and weight of the drive unit, while making the drive unit more compact can limit the amount of force and stability it can deliver. For this reason, robot reducer companies continue to research reducer structures that can achieve high torque, high durability, and compact size at the same time, and cycloid reducers are gaining attention as a solution that can meet these requirements.
Structural Strengths of Cycloidal Reducers
As the name suggests, a cycloid reducer applies a tooth profile based on a cycloidal curve. A cycloidal curve is the path traced by a point on a circle as the circle rolls, and unlike the tooth shapes of typical gears, it has a smooth, curved form. Based on this curved tooth structure, cycloid reducers transmit power in a different way than conventional gear reducers.
Their most notable characteristic is how they distribute load. With a cycloidal tooth profile, load is not concentrated on a single tooth surface but is spread across multiple contact surfaces. This reduces the strain placed on the drive unit even in environments where high loads are repeatedly applied, allowing for stable torque transmission. This characteristic is especially advantageous for achieving high durability in collaborative robots, large AMRs, and logistics handling equipment that perform repetitive transport tasks.

This structure also helps reduce wear and damage to the tooth profile, maintaining consistent performance even during long, continuous operation. This benefits component lifespan and maintenance, and also has a positive effect on the operating efficiency of logistics automation equipment that runs for extended periods.
In addition, the structural characteristics of cycloidal reducers allow for a relatively high reduction ratio even in a single stage. This makes it possible to secure the necessary torque while reducing the thickness of the drive unit, enabling a more compact design. A thinner drive unit not only allows for more efficient use of internal installation space but also helps reduce the overall size and weight of the equipment.
In summary, cycloid reducers offer structural advantages that can simultaneously meet the key requirements for robot reducers: high torque, strong durability, and a thin structure. As the range of applications for automated robots continues to expand, the importance of compact reducers that balance these performance factors is only growing, and it has become essential for robot reducer companies to build product lineups and technical capabilities that can meet these market demands.

The BSR Cycloidal Reducer, Increasing Design Freedom for Drive Units
In line with this trend, Bonsystems offers drive solutions built on proprietary cycloidal reduction technology. Our flagship product, the BSR series, is a cycloid reducer developed with high torque, high durability, and compact size in mind, all requirements for automated robots.
A key feature of the BSR series is its ability to deliver high torque even with a slim profile. This makes it possible to build efficient drive systems even in robots with limited installation space, and also supports further miniaturization of the drive unit. As the drive unit takes up less space, design freedom inside the robot increases, allowing for a larger battery capacity or more efficient placement of sensors, control units, and other components.

In terms of durability as well, the BSR series effectively reflects the strengths of the cycloidal structure. It is designed with a load-distributing structure that helps maintain durability even under repeated, high-load operating conditions.
The BSR 070 and 080 lines use a pinless design that achieves high rigidity while also supporting quality consistency and productivity. Compared to conventional pin-gear types, the simpler component structure improves assembly convenience and reduces process variation, helping ensure consistent quality even in high-volume production environments. This structural simplicity can also ease the burden of maintenance work and improve operational efficiency.
In this way, the BSR series is a reducer that, based on its cycloidal structure, achieves a balance of high torque output, strong durability, and compact size through its thin profile, and it is being used as a solution for a variety of drive environments in mobile robots and logistics automation equipment.
We are a robot reducer company providing cycloidal reducers suited to the drive environments of next-generation robots. We will continue to develop drive solutions that can meet the demands of a wide range of industrial settings and support our customers in designing their robot systems. If you are looking for a compact reducer solution suited to the collaborative robot you are developing, or would like more detailed information on the BSR reducer, please feel free to reach out through our website at any time.

FAQ
Q. What are the criteria for selecting a reducer for AGVs and AMRs?
A reducer for robots should be selected not only based on torque output but also by considering the load variations that occur during actual operation. Because load and driving conditions in logistics and manufacturing environments change frequently, a reducer needs both reliable torque transmission and structural durability that can withstand repeated loads. It is also important to consider whether the reducer can maintain stable performance under repeated starts, stops, and acceleration or deceleration.
Q. How is a cycloid reducer different from a conventional gear reducer?
A cycloid reducer transmits power through a curved tooth structure. Compared to a conventional gear reducer, its structural feature is that force is distributed across multiple contact surfaces rather than concentrated at a single point. This helps reduce the strain on internal components in drive environments where high loads are repeatedly applied, and supports stable torque transmission.
Q. Why do robot reducer companies focus on miniaturizing drive components?
Automated robots need to fit motors, reducers, batteries, sensors, and control units all within a limited space. If the drive unit takes up more space, it can affect the overall size and weight of the equipment. For this reason, compact reducers that can still deliver sufficient torque within a small structure are an important consideration in actual design work, as they help improve the space efficiency and design freedom of mobile robots.
Q. What advantages does the Bonsystems BSR reducer offer for automated robot design?
The BSR series is a reducer lineup based on a cycloidal structure, designed to deliver high torque even with a thin profile. It can be used to build compact drive systems in AGVs, AMRs, and other equipment that need to fit a drive unit into a limited space. It is also available in a wide range of reduction ratios, from 19:1 to 99:1, allowing users to select the right product based on the size and requirements of their equipment.
