
As the service robot and humanoid robot markets expand rapidly, design requirements for joint drive units are becoming increasingly demanding. Since sufficient torque and durability must be achieved within compact spaces, selecting the right reducer is one of the critical challenges in drivetrain design. These components come in various types, each suited to different application environments based on their structural characteristics. In this article, we look at the role of the robot reducer, then briefly explore which reduction technologies are gaining attention in the robotics field today.
Table of Contents
The Role of the Robot Reducer
Key Summary In a robot’s drivetrain, reduction technology converts the motor’s high-speed rotation into the speed and torque suited to the robot’s movements, enabling smoother and more stable operation. In modern robots, the reducer is often integrated with the motor in the form of an actuator.
In the drivetrain that powers a robot, reduction technology plays a vital role. When we talk about driving force, motors are usually the first thing that comes to mind. Because motors inherently spin at high speeds, connecting them directly to a robot’s joints or drive units makes it difficult to deliver the required force in a stable manner.
This is where the robot reducer comes in. It converts the motor’s rotational output into the speed and torque appropriate for the robot’s movements, enabling smoother and more stable operation. Reducers also influence the accuracy and stability of joint movement.
A key factor to consider here is backlash, the slight gap or play that occurs when gears mesh together. When backlash is large, small errors can arise when the robot changes direction, resulting in instability such as wobbling or less stable motion.
In short, the robot reducer is a core component that determines how smoothly and accurately a robot can move. In modern robots, reducers are often integrated with motors in the form of actuators rather than used in isolation. These actuators form a critical foundation that defines the robot’s overall drive performance and task quality.

Characteristics of the Cycloidal Reducer
Key Summary Cycloidal gear reduction technology transmits power based on the principle of cycloidal motion and has a load-distribution characteristic through surface contact. This structural property is favorable for durability in environments with frequent repetitive motion and enables stable power transmission even under external impact or varying loads.
When designing service or humanoid robots, it is important to consider both the structural characteristics of the robot reducer and the intended application environment. Cycloidal gear reduction technology is gaining recognition as a reduction method well suited to modern robot development, especially in terms of durability and drive stability.
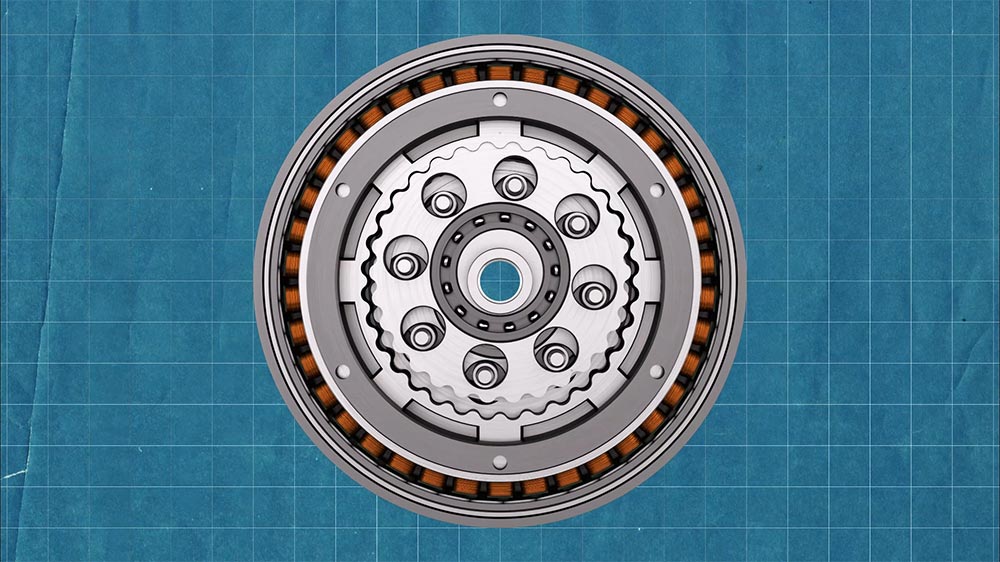
It transmits power based on the principle of cycloidal motion, and features a load-distribution characteristic through surface contact. This structural property is advantageous for ensuring durability in environments with frequent repetitive motion, and enables stable power transmission even under conditions involving external impact or varying loads.
In particular, robot joint drive units involve continuous cycles of stopping, rotating, and changing direction, making the structural stability and performance of the reducer especially important. In this regard, cycloidal reduction technology is drawing attention as one of the applicable methods for joint drive systems in service and humanoid robots.
Bonsystems has focused on the advantages of cycloidal technology and has continued its own research, based on proprietary reduction gear design expertise, to make it even more effectively applicable to real-world robot drivetrain design.
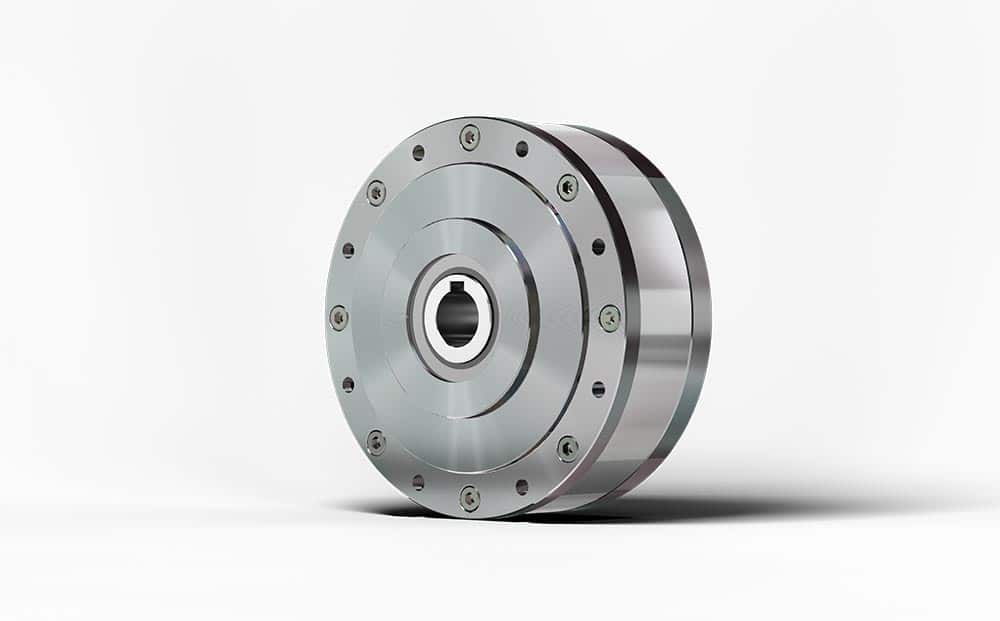
Our robot reducer, the BSR, is the product of this research, developed by optimizing the characteristics of the cycloidal structure for actual hardware design. It delivers high output even in a thin profile, and offers a wide range of reduction ratio options to accommodate diverse design requirements. Backed by these advantages, the BSR is being utilized as a reduction solution that can be applied broadly to robot joint drive units and actuator designs.
The Cycloidal Reducer Leading the Future Robotics Industry
Key Summary As robots become more compact and the collaborative robot market grows, the demand for reducers that are both smaller and capable of higher torque output continues to rise. Bonsystems supports robot drive design through its reducer and actuator technology, offering custom manufacturing through direct customer consultation.
Going forward, as robots become more compact and the collaborative robot market continues to grow, the demand for reducers that are both smaller and capable of delivering higher torque output will only increase.
In this context, our solution is a well-suited choice for modern robot manufacturing, offering strong torque, durability, and stability together.
We support robot drive design through our reducer and actuator technology. Beyond supplying core robot components, we offer custom manufacturing services through direct customer consultation, proposing solutions tailored to your specific use case and requirements.
If you need custom robot reducer and actuator development or robot development solutions, please submit an inquiry through the Bonsystems website.
FAQ
Q: Why is a robot reducer necessary?
A: Motors inherently rotate at high speeds, making it difficult to deliver stable force when connected directly to robot joints. The reducer converts this rotational output into the speed and torque appropriate for robot operation.
Q: Why is the cycloidal reducer gaining attention for service and humanoid robots?
A: Robot joint drive systems must be packaged into compact spaces while constantly repeating motions such as stopping, rotating, and changing direction. Its surface-contact structure, based on the cycloidal motion principle, evenly distributes the load, making it well-suited to maintaining durability and drive stability even in environments with frequent repetitive motion. These characteristics are why it is considered appropriate for robot joint drive systems.
Q: What makes the Bonsystems BSR reducer highly versatile?
A: The BSR delivers high output even with a thin profile, and its wide range of reduction ratio options allows it to meet diverse design requirements. It can be applied broadly to joint drive units and actuator designs where space constraints and performance demands must be addressed simultaneously.
Q: What information should I prepare when inquiring about reducers or actuators?
A: It helps to have the following ready: the type of robot being used, joint drive unit design data, the required reduction ratio and torque specifications, and the motor specs. Providing the operating environment and delivery schedule as well will allow us to propose a more specific and tailored solution.
